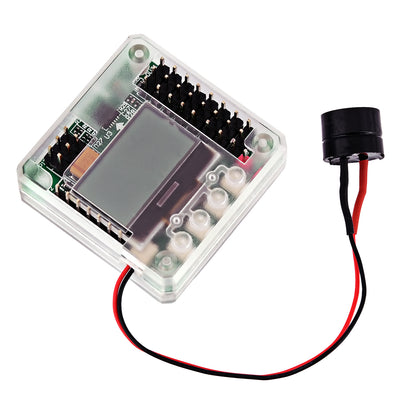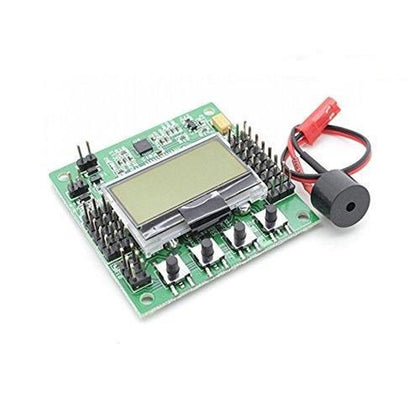
KK Multicopter V5.5 Controller Black Board

![KK V5.5 four axis flight control board for quadcopter and multirotor drone]()

![KK V5.5 flight controller circuit board for DIY quadcopter and RC drone projects]()

![KK four axis flight control board V5.5 for multirotor aircraft stabilization]()

![KK V5.5 four axis flight control board for quadcopter and multirotor drone]()

![KK V5.5 flight controller circuit board for DIY quadcopter and RC drone projects]()

![KK four axis flight control board V5.5 for multirotor aircraft stabilization]()

The board supports multiple aircraft configurations, including Quadcopter X, Quadcopter +, Tricopter, Hexacopter, Y6, and fixed-wing models, depending on the installed firmware. Featuring adjustable gyro sensitivity, standard RC receiver inputs, ESC/servo outputs, and a 45 × 45mm mounting pattern, it is suitable for DIY drone assembly, aeromodelling, and educational multirotor projects.
-20%


KK Multicopter V5.5 Controller Black Board
Disponible:En stock
- SKU del producto: KG260
₹ 1,599
₹ 1,999
Need Volume Discounts? Deals are specially designed for you. Click here
Need Customization? Provide us more details Click here
🏠
Warehouse Details:

Specification
Descripción
KK Multicopter V5.5 Controller Black Board
The KK Multicopter V5.5 Flight Controller Board is a compact and lightweight multi-rotor flight control board designed for quadcopters, tricopters, hexacopters, and compatible fixed-wing aircraft projects. Powered by an ATmega168PA 8-bit AVR microcontroller, this controller uses three ENC-03RC single-axis gyroscope sensors to detect rotational movement and help stabilize aircraft during flight.The board supports multiple aircraft configurations, including Quadcopter X, Quadcopter +, Tricopter, Hexacopter, Y6, and fixed-wing models, depending on the installed firmware. Featuring adjustable gyro sensitivity, standard RC receiver inputs, ESC/servo outputs, and a 45 × 45mm mounting pattern, it is suitable for DIY drone assembly, aeromodelling, and educational multirotor projects.
Features
- ATmega168PA 8-bit AVR microcontroller
- Three ENC-03RC single-axis gyroscope sensors
- Supports multiple multirotor configurations
- Compatible with Quadcopter X and + flight modes
- Adjustable Roll, Pitch, and Yaw gyro sensitivity
- Standard RC receiver signal inputs
- Supports compatible ESC and analog servo outputs
- Compact and lightweight PCB construction
- 45 × 45mm mounting hole spacing
Working Principle
The KK Multicopter V5.5 Controller operates using an ATmega168PA microcontroller and three single-axis gyroscopes that measure rotational movement along the Roll, Pitch, and Yaw axes.
The microcontroller processes the RC receiver inputs and gyroscope signals to adjust the output signals sent to connected Electronic Speed Controllers (ESCs) or servos. These adjustments help maintain aircraft rotational stability and respond to pilot commands. The board uses gyroscope-based stabilization rather than GPS or accelerometer-based automatic leveling.
The microcontroller processes the RC receiver inputs and gyroscope signals to adjust the output signals sent to connected Electronic Speed Controllers (ESCs) or servos. These adjustments help maintain aircraft rotational stability and respond to pilot commands. The board uses gyroscope-based stabilization rather than GPS or accelerometer-based automatic leveling.
Supported Model Types
- Aero / Fixed-Wing Aircraft
- Dualcopter
- Tricopter
- Quadcopter X Configuration
- Quadcopter + Configuration
- Hexacopter
- H6 Copter
- Y6 Copter
Receiver and ESC Connection
- Aileron: Receiver Roll Signal Input
- Elevator: Receiver Pitch Signal Input
- Throttle: Receiver Throttle Signal Input
- Rudder: Receiver Yaw Signal Input
- M1–M6: Motor ESC or Servo Outputs, depending on firmware
- Signal (S): PWM Control Signal
- Positive (+): Supply Connection
- Ground (-): Common Ground Connection
Technical Details
- Item Type: Multirotor Flight Controller Board
- Model: KK Multicopter V5.5
- PCB Color: Black
- Microcontroller: ATmega168PA
- Controller Architecture: 8-Bit AVR RISC
- Gyroscope: ENC-03RC × 3
- Stabilization: Three-Axis Gyroscope-Based
- Input Voltage: 3.3–5.5V DC (Specified)
- Receiver Signal: Approximately 1520µs Center PWM
- ESC Signal: Standard RC PWM Output
- Receiver Channels: 4
- Motor/Servo Outputs: Up to 6, Firmware-Dependent
- Adjustment: Roll, Pitch, and Yaw Potentiometers
- Supported Flight Modes: Normal and Sport, Firmware-Dependent
- Mounting Hole Spacing: 45 × 45mm
- Mounting Hole Diameter: Approximately 3mm
- Firmware Programming: Compatible AVR ISP Interface
Applications
- DIY quadcopter and multirotor construction
- Tricopter and hexacopter flight control
- RC aircraft stabilization projects
- Drone control and aeromodelling experiments
- Gyroscope-based stabilization projects
- Educational robotics and UAV projects
Physical Attributes
- Board Length:50mm
- Board Width:49mm
- Board Height:14.5mm
- Weight:18g
- Mounting Hole Spacing: 45 × 45mm
- PCB Color: Black
Installation and Usage Instructions
- Mount the flight controller securely on the aircraft frame.
- Position the board in the correct orientation according to the firmware instructions.
- Connect the RC receiver channels to the corresponding inputs.
- Connect the ESC or servo signals to the required motor outputs.
- Provide a compatible regulated power supply.
- Configure the required aircraft type and firmware.
- Adjust the Roll, Pitch, and Yaw potentiometers as required.
- Verify receiver input, motor mapping, and rotation direction.
- Perform initial testing without propellers.
Frequently Asked Questions (FAQs)
- Which microcontroller is used? ATmega168PA 8-bit AVR.
- How many gyroscopes are included? Three ENC-03RC single-axis gyroscopes.
- Does it support Quadcopter X and +? Yes, with compatible firmware.
- Can it control a hexacopter? Yes, with appropriate six-motor firmware.
- Does it support auto-leveling? No, the board provides basic gyroscope-based stabilization.
- Can the firmware be updated? Yes, using a compatible AVR ISP programmer.
Safety Precautions
- Use a compatible regulated power supply.
- Check receiver and ESC pin connections carefully.
- Ensure correct board orientation and motor mapping.
- Remove propellers during setup and calibration.
- Secure the flight controller against excessive vibration.
- Perform controlled ground testing before flight.
Package Includes
- 1 × KK Multicopter V5.5 Flight Controller Black Board
- 1 × Set of 3-Pin Connecting Cables
- 1 × 3-Pin Common to 3 Separate Connectors Cable Set